Chapter 4 Circuit Design of Air Pressure Control System
Goto Zulie teacher teaching network Pneumatic hydraulic control practice
4-1 Basic Steps of Circuit Design for Pneumatic System TOP
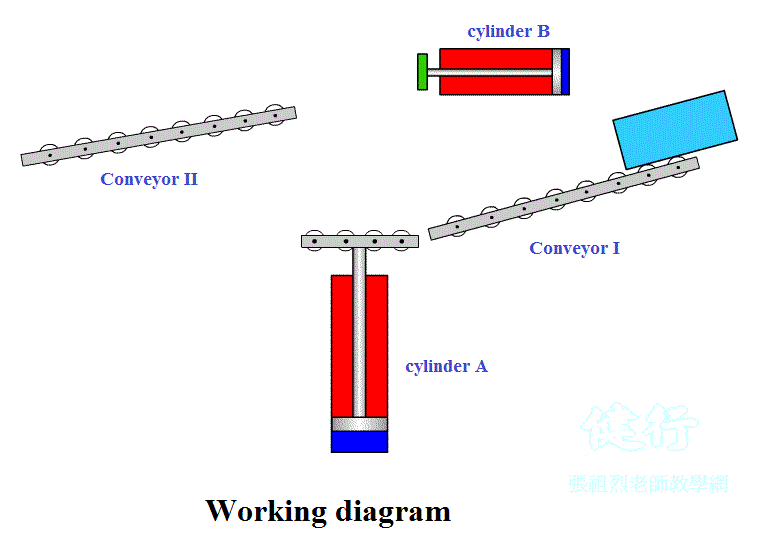
Step 1: Draw a working diagramP137
Step 2: Write the movement sequence of the pneumatic cylinder in the system
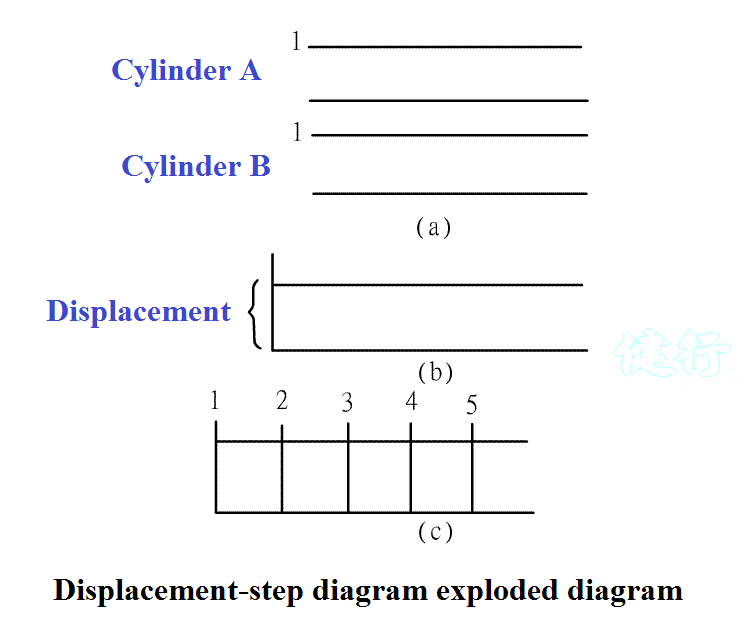
(1) Travel-step diagram TOP
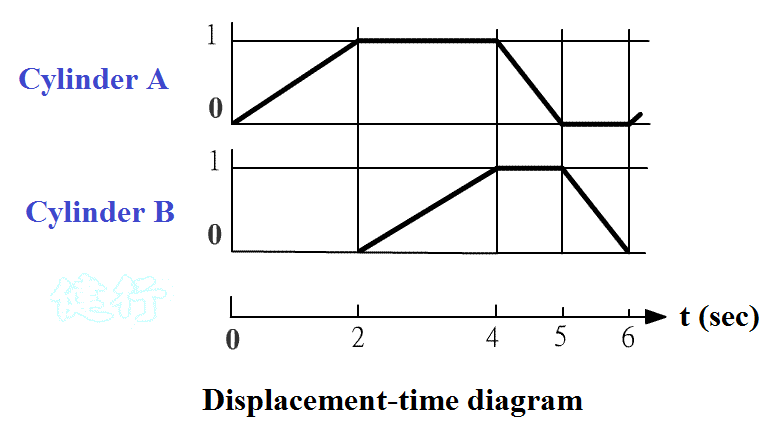
(2) Travel-time diagram (also known as time-travel diagram) TOP
Step 3: Design
the air pressure control circuit according
to the function chart ( or
control signal chart ) TOP
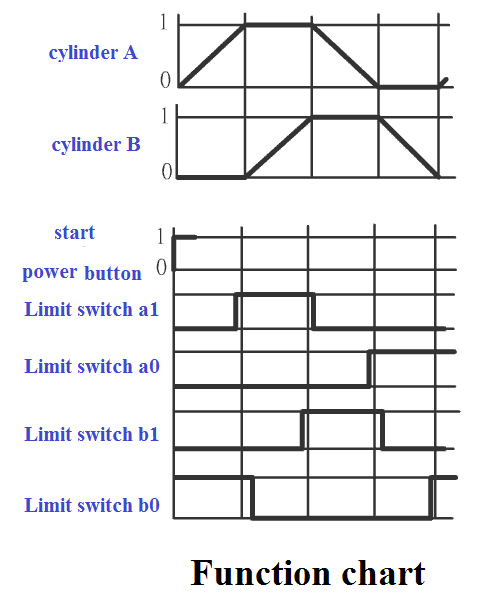
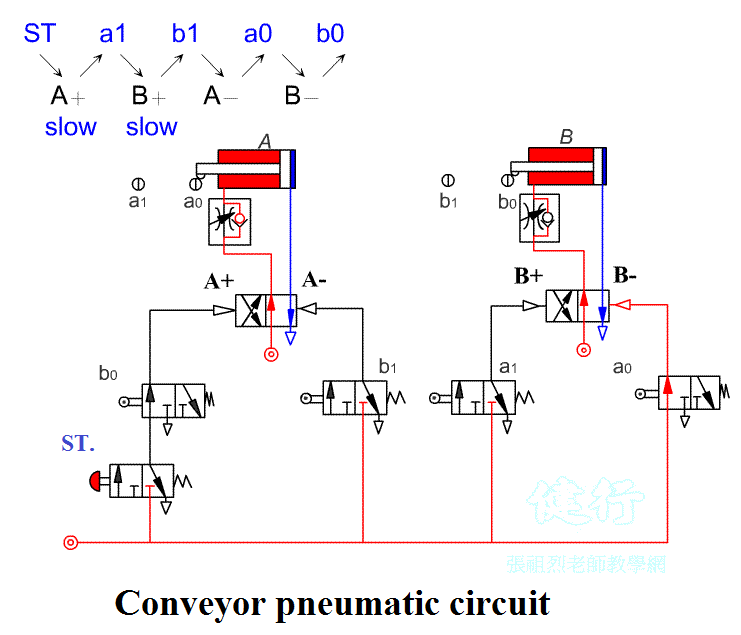
Step 4: Create Component usage table TOP
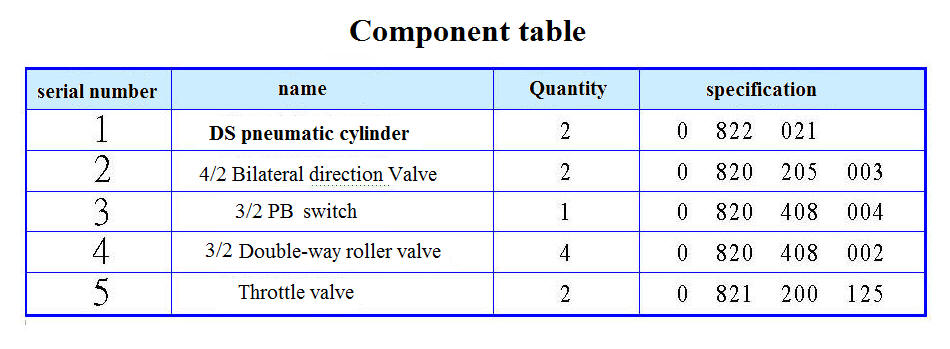
The air pressure control circuit discussed in this chapter is mainly based on the traditional pure pneumatic control. Its operating pressure is 3 to 8 kgf / cm2 , the output is between 0 to 3000 kgf, and the speed is between 0.5 to 1.5 m/sec . The following is Several commonly used pure pneumatic circuit design methods.
1 . Intuitive method.
2 . Cascade method.
3 . Cycle step method.
4-2 Intuitive method (Method or Intuition) the TOP
Signal processing method of this design
embodiment has the following ways:
1. The standing-wave
signal [ stagnation (Standing) mode ] :
It is used
for general signals. Installed at the end of the stroke of the pneumatic
cylinder with two-way rollers to generate standing wave signals, as shown in
Figure 4-8.
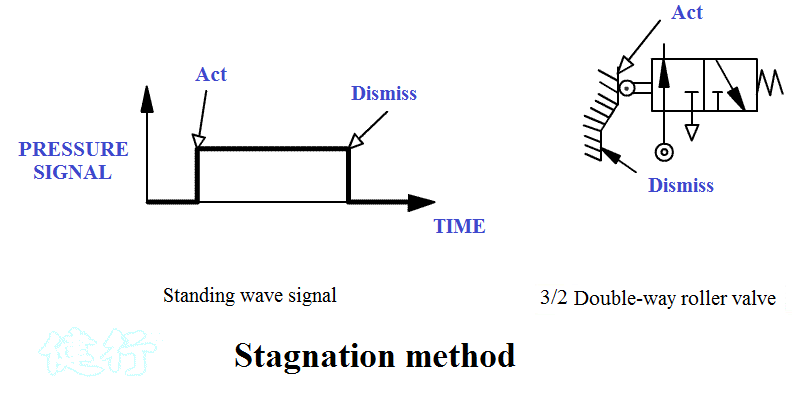
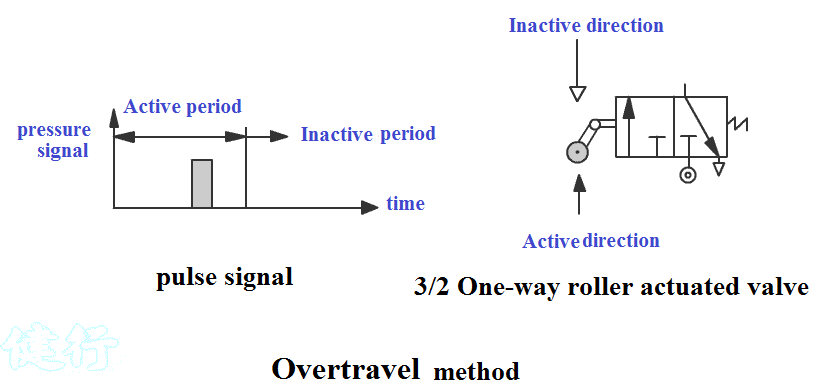
2. The pulse signal [ overstroke (over travel) mode ] : It is used for interference signal. Installed on the inner side of the end of the stroke of the cylinder with a unidirectional roller. After touching it, it will generate pulse signal. TOP
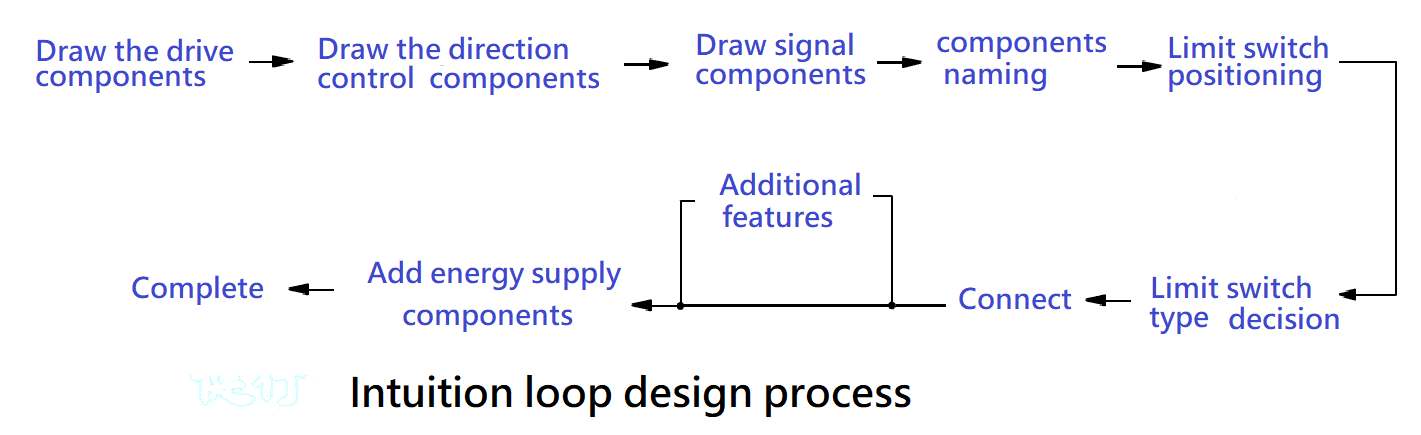
Intuitive design of the pneumatic circuit can use the method of Figure 4-10 to performone by one TOP
======================================================= =====================

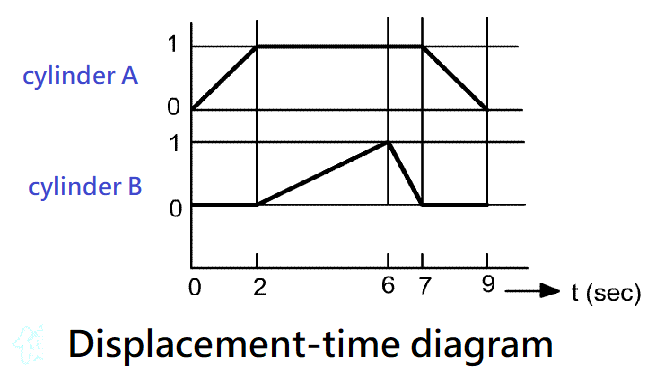
(b) Draw a motion picture , which is represented by a displacement time diagram, as shown in Figure 4-12 . At the same time, its exercise sequence is listed in abbreviation: A + B + AB- TOP
(c) Mapping the air pressure circuit TOP
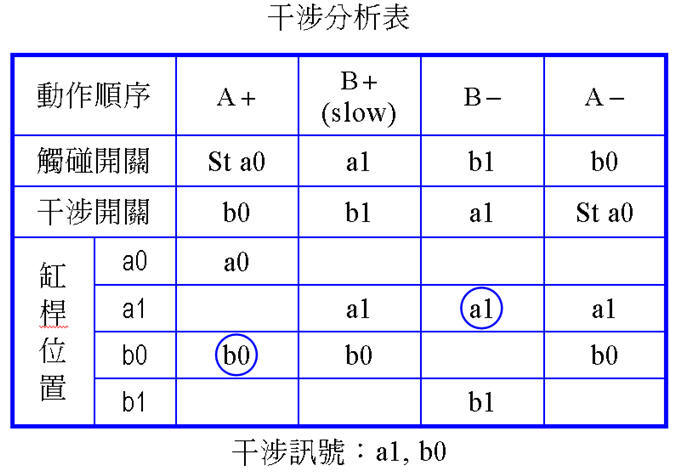
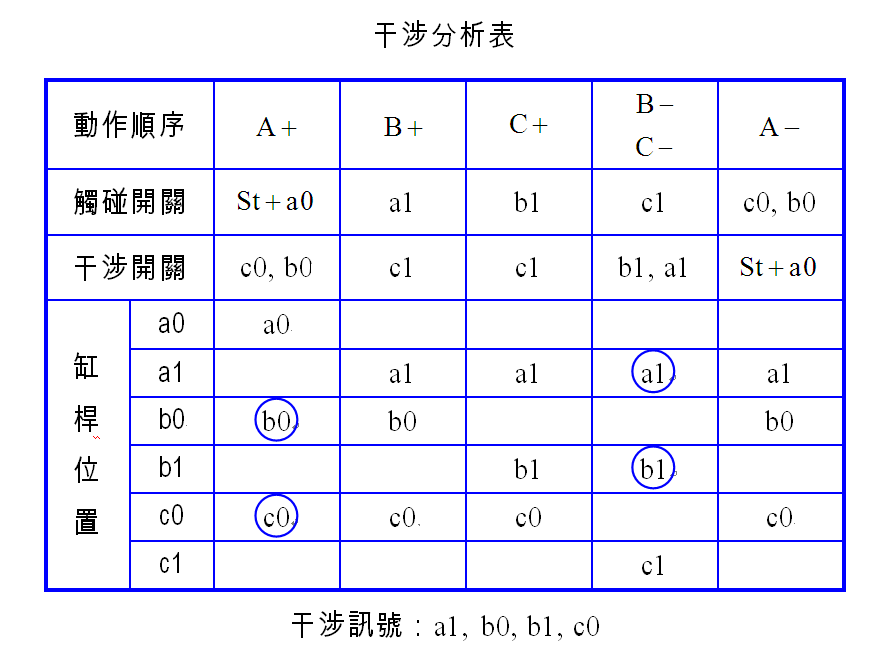
Determine the operation method used by the limit switch ( Unidirectional or bidirectional roller ) : When the signal conflict on the two sides of the direction control element is caused, the interference signal needs to be processed into a pulse signal by overtravel ( that is, the limit switch must be unidirectional Roller and move inward ) . The remaining signal elements are actuated by two-way rollers. May be established below the interference analysis table analysis of
Example 4-2 rivet riveting machine pneumatic control circuit design TOP
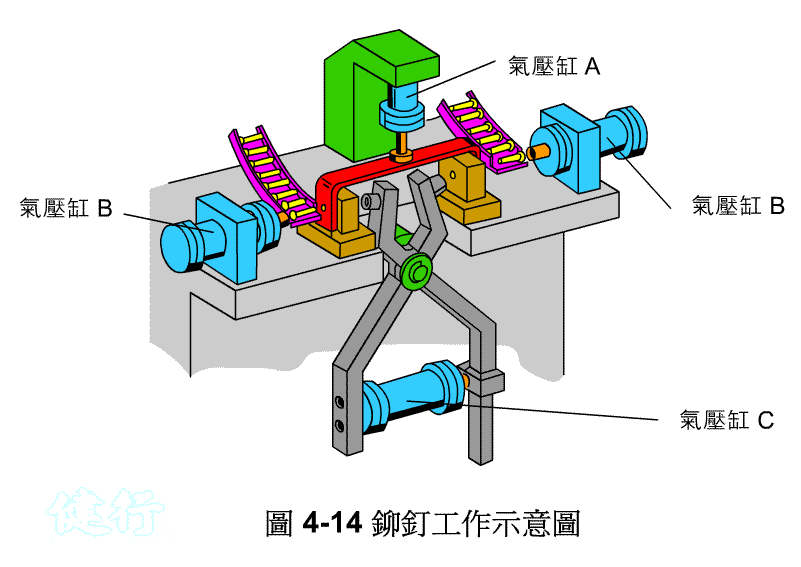
(a) Working diagram
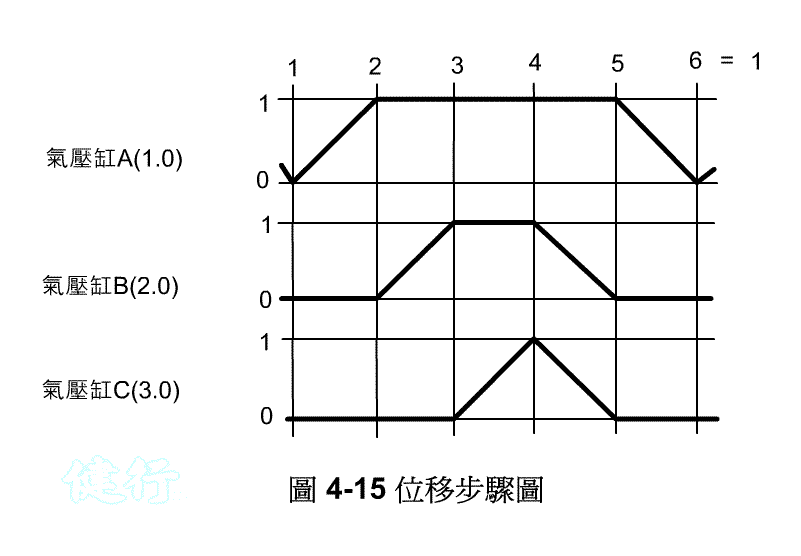
(b) Displacement Time FIG TOP
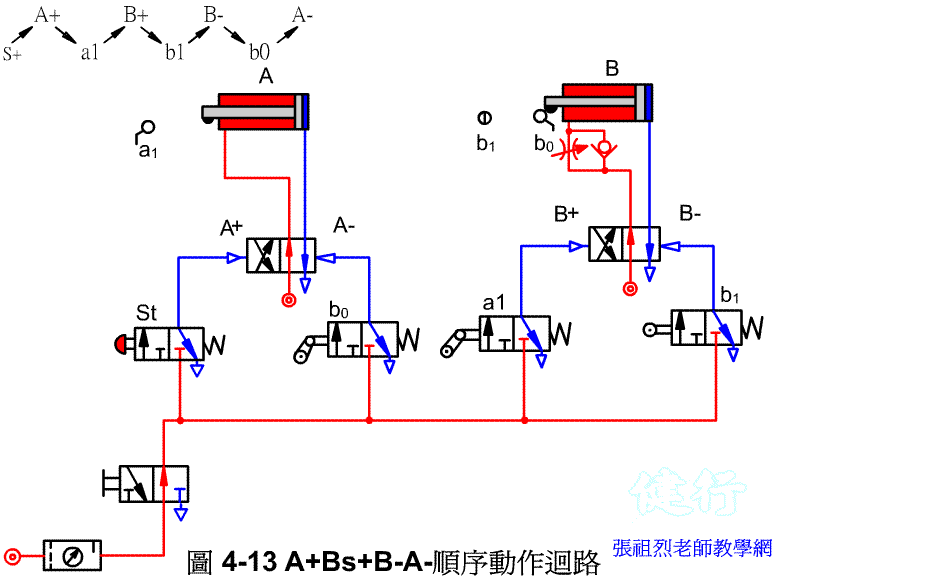
(c) Pneumatic Circuit TOP
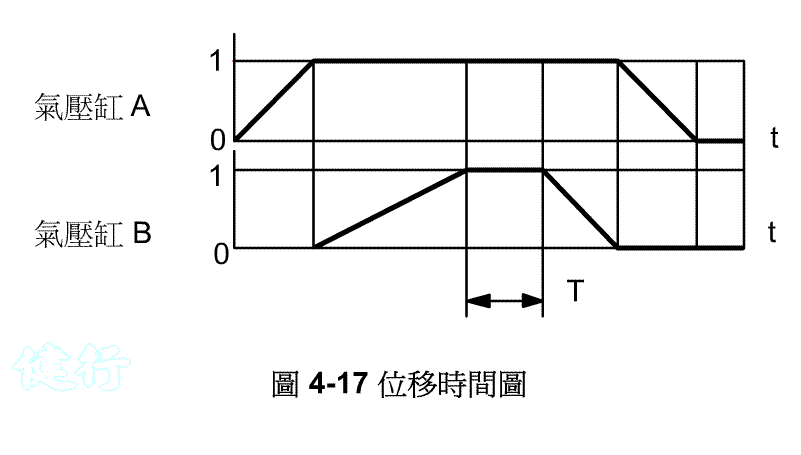
Example 4-3 Design of air pressure control loop for drilling. (a) Displacement time diagram. TOP
exercise sequence is: A + B slow +
B- A-.
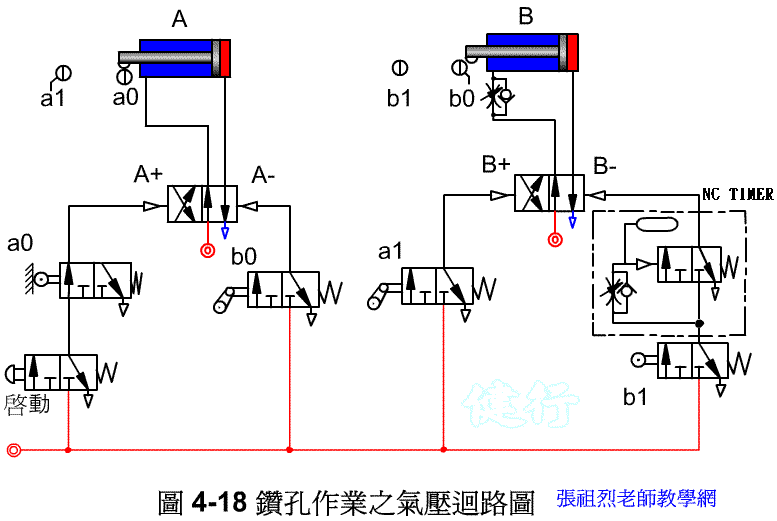
(b) Pneumatic Circuit TOP
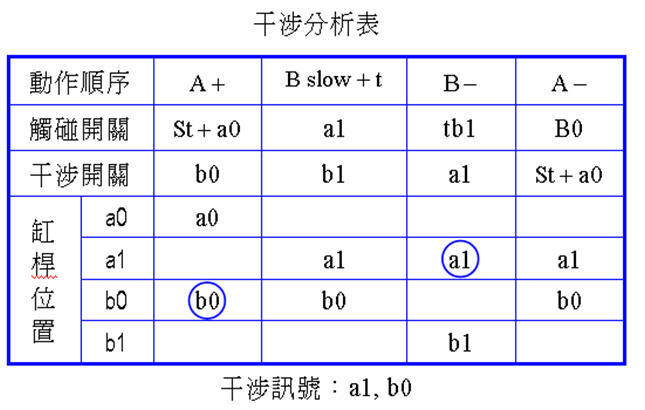
The interference signals are a1 and b0 . Change the single roller to move inward in overtravel mode.
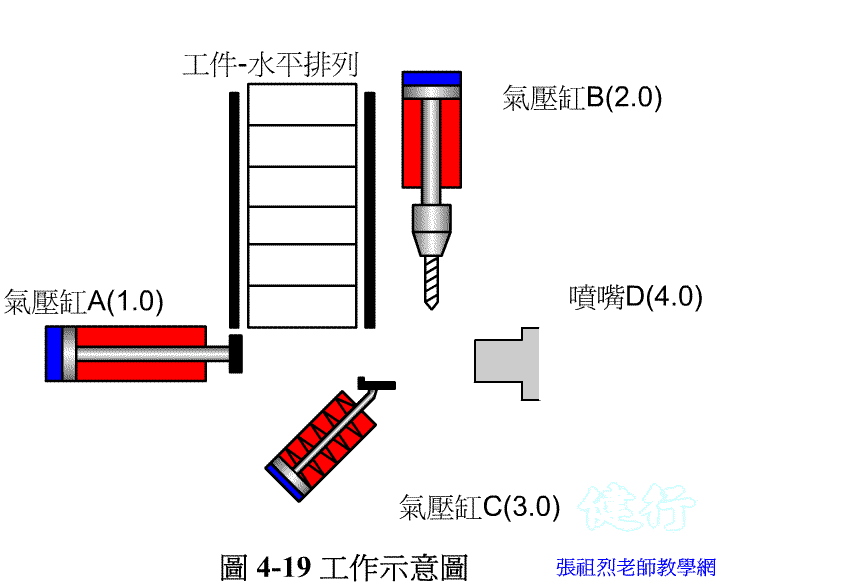
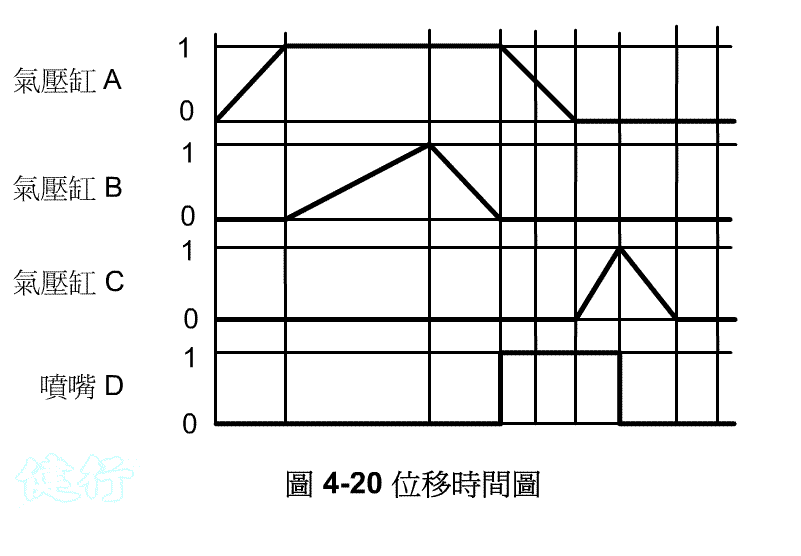
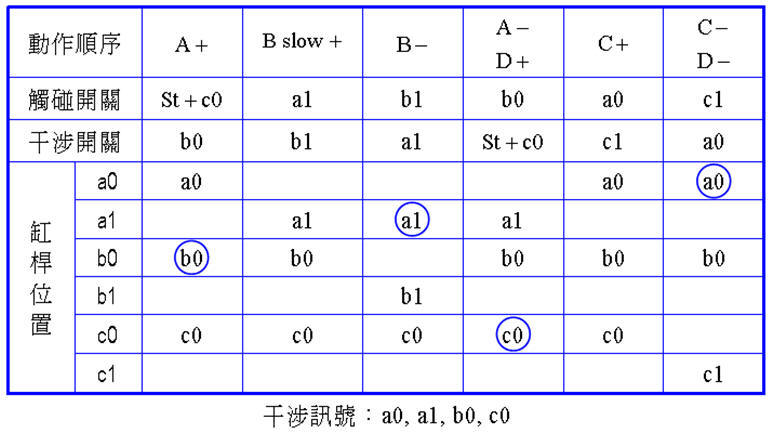
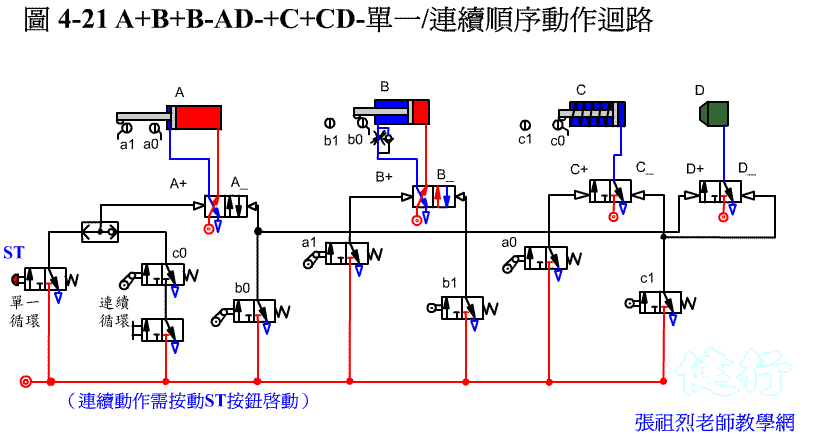
Example 4-4 Design of a pneumatic control circuit for automatic drilling and unloading with single cycle operation and continuous processing cycle functions TOP
(a) Working diagram
(b) Displacement Time FIG TOP
(c) Pneumatic Circuit TOP
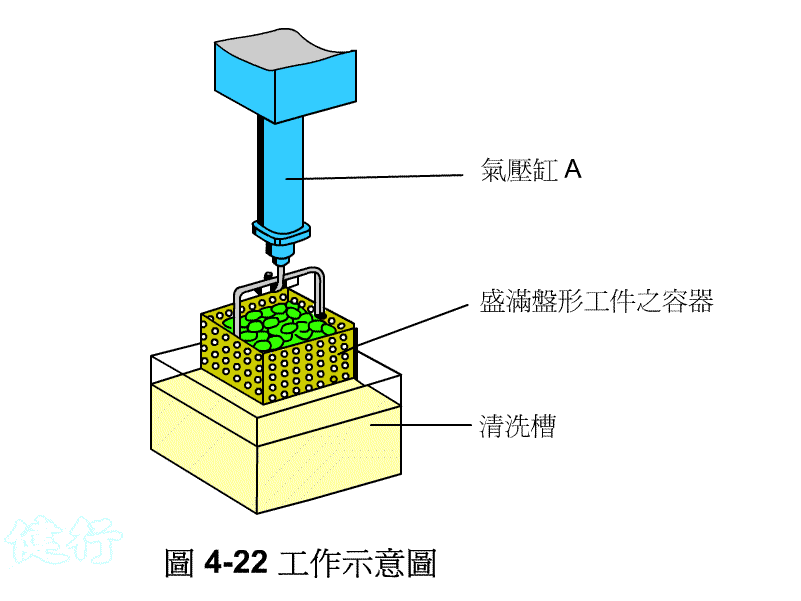
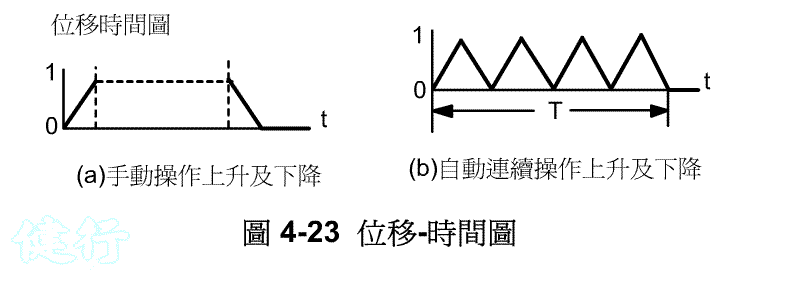
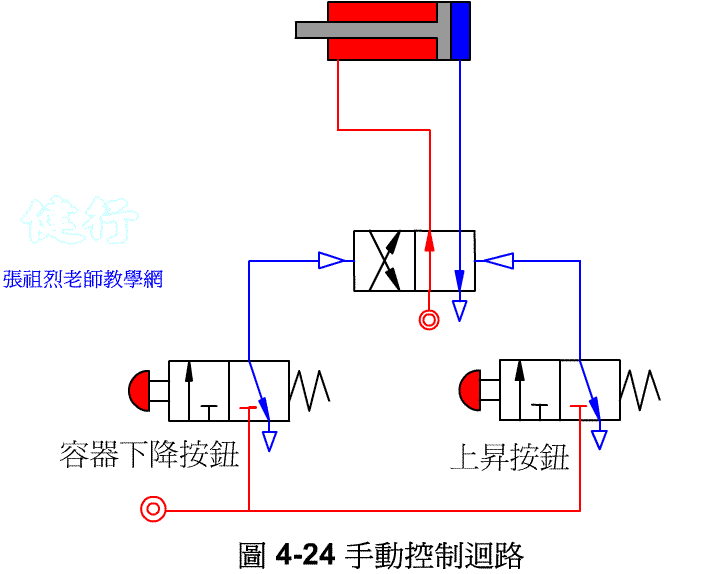
Example 4-5 Design of pressure control circuit for chemical cleaning the container. TOP
(a) Working diagram
(b) Displacement Time FIG TOP
(c) Pneumatic Circuit TOP
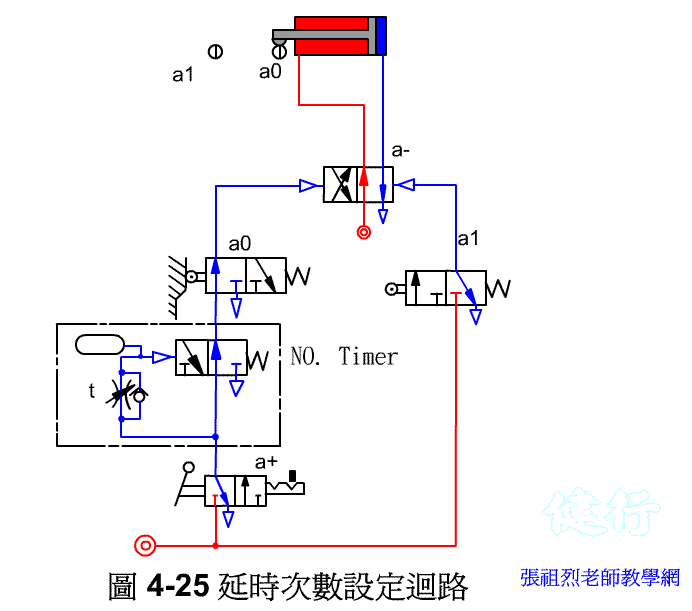

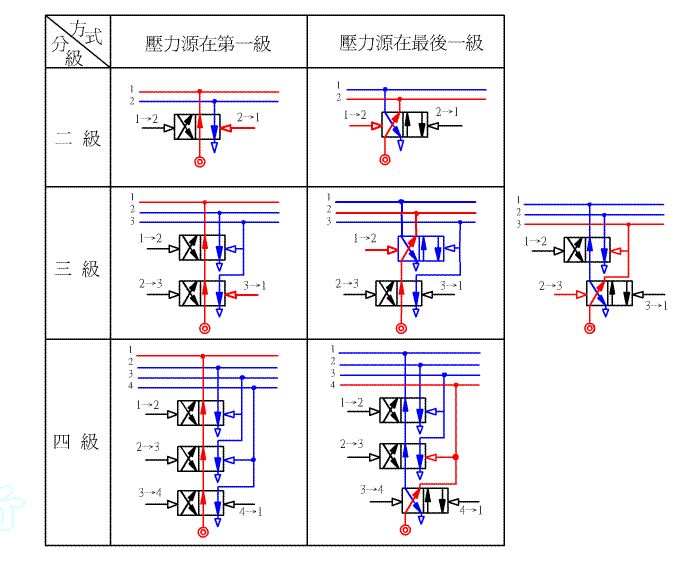
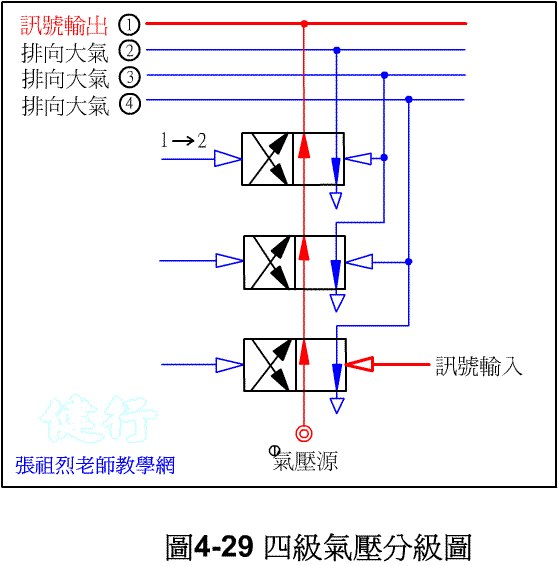
The method of cascade uses the signal transfer action of the 4/2 ( or 5/2) bilateral pneumatic valve ( or reversing valve ) to enable complex control to ensure that only one signal is output per action:
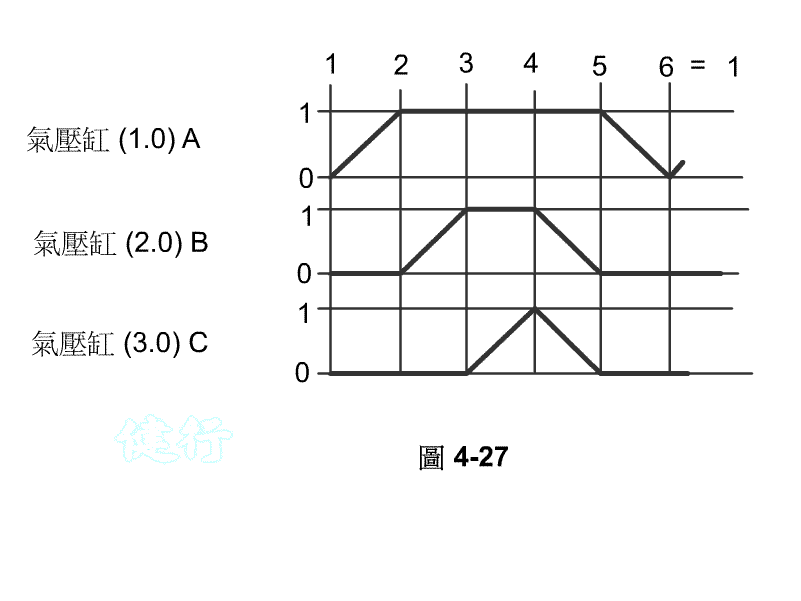
Take Figure 4-27 as an example:
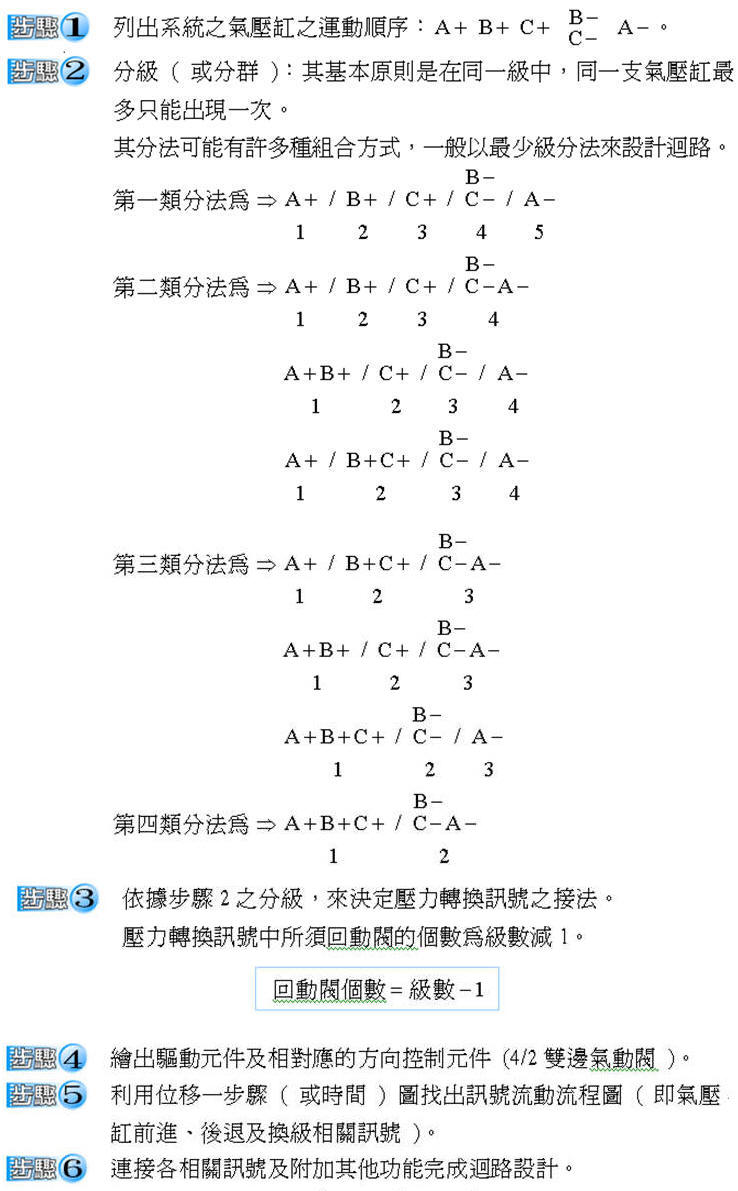
How to grade? TOP
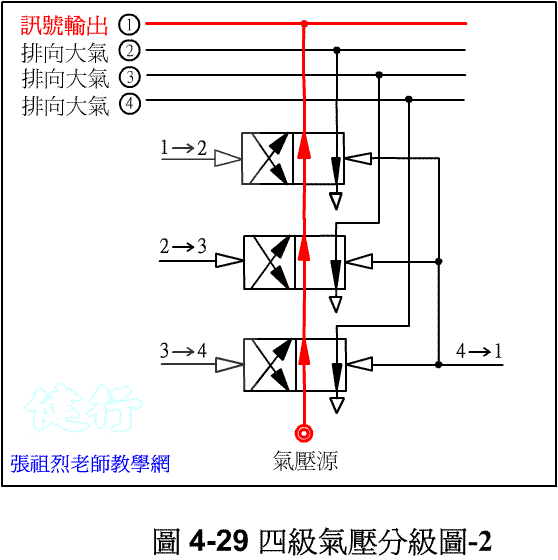
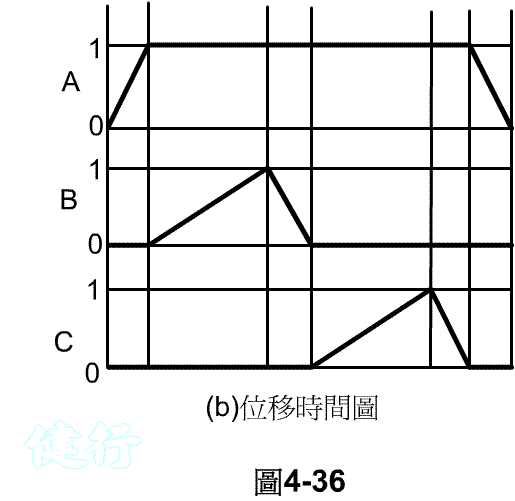
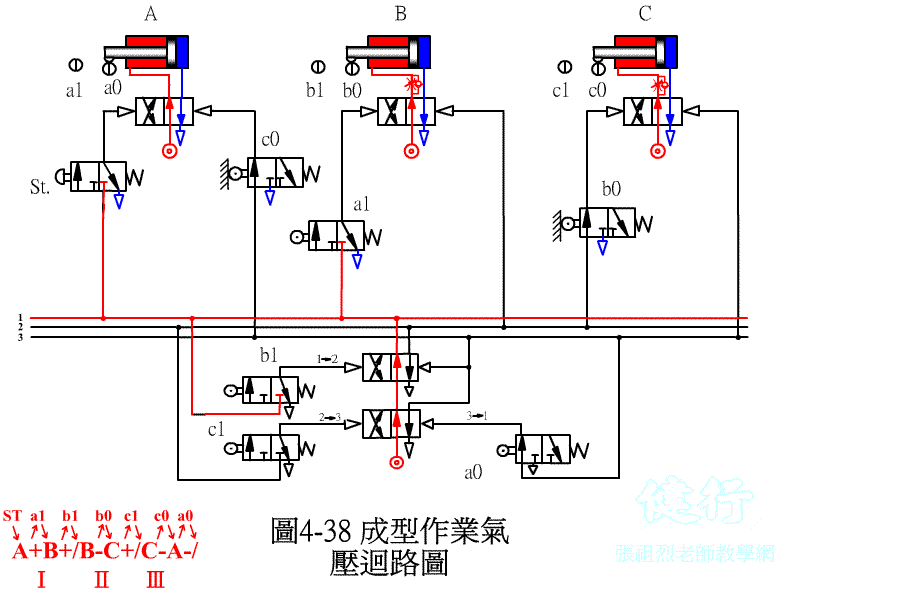
Example 4-6 Try to design the following air pressure control circuit by cascade method. TOP
displacement time chart is shown
in Figure 4-33 .
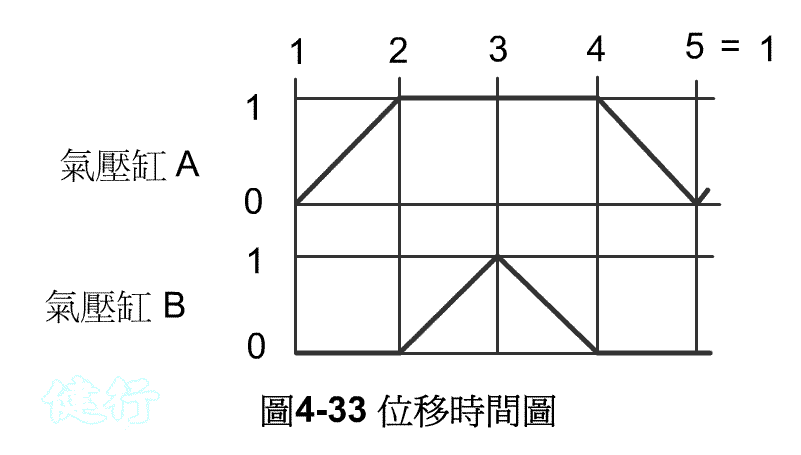
Step 1 : List exercise sequence TOP
Step 2 : Classification. 
Step 3 : Draw the pressure conversion signal.
Step 4 :
Draw the drive element, direction control element and limit switch positions and
name them alphabetically.
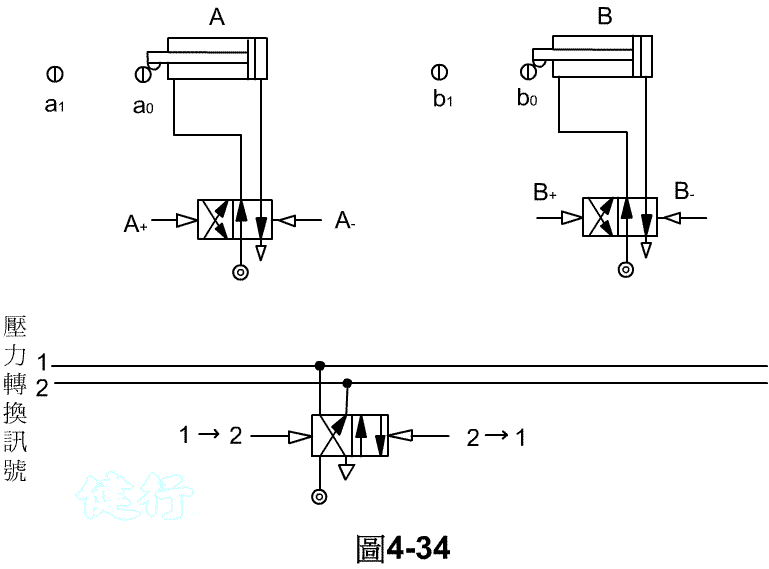
Step 5 : List the signal flow and connect the relevant signals to complete the loop. TOP
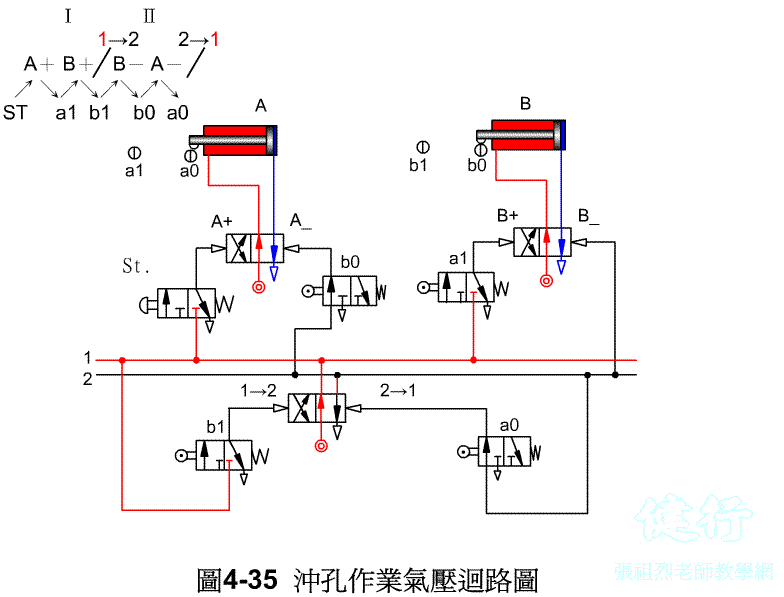
Example 4-7 Try to design the air pressure control circuit in the sequence of action diagram. TOP


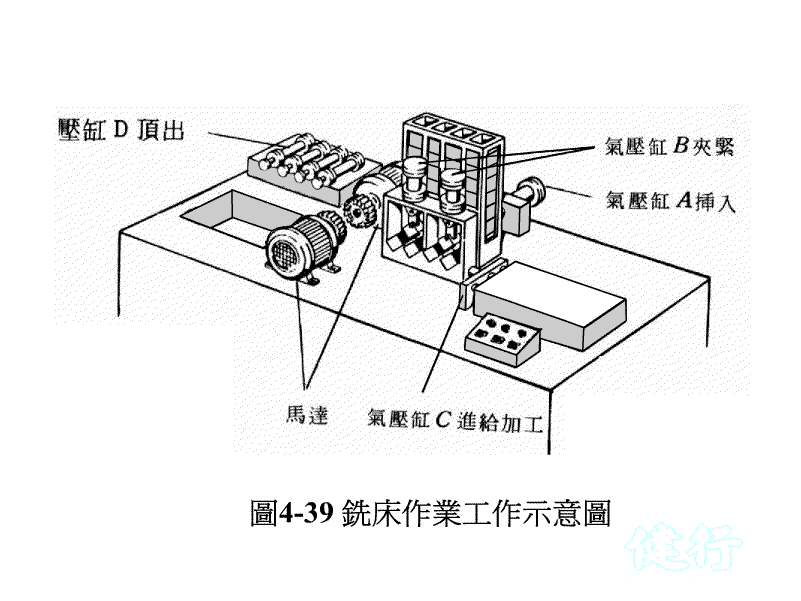
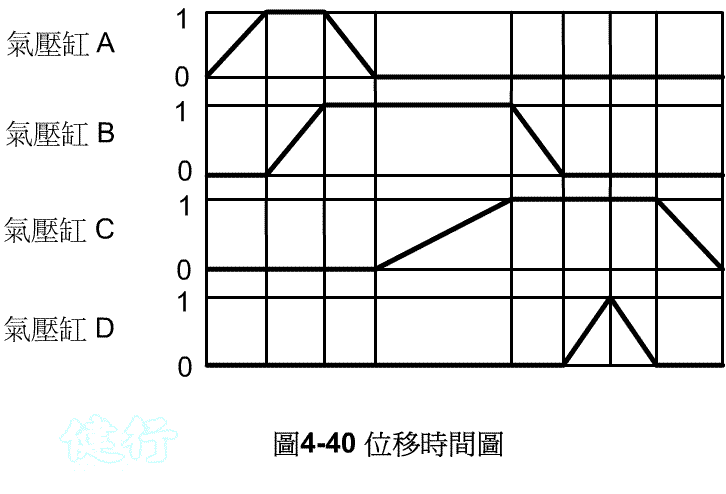
Example 4-8 Milling working displacement time of milling machine is shown in Figure 4-40. TOP
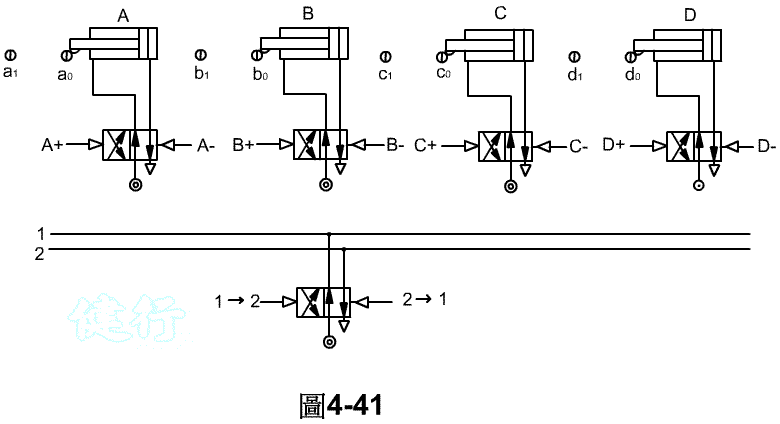
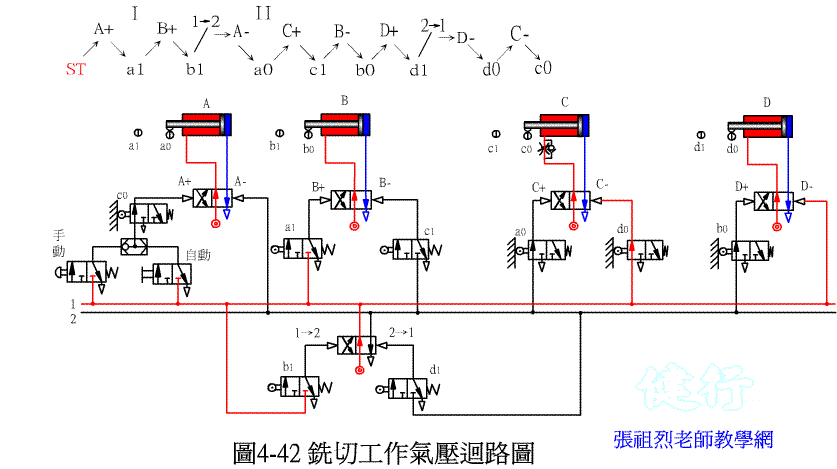
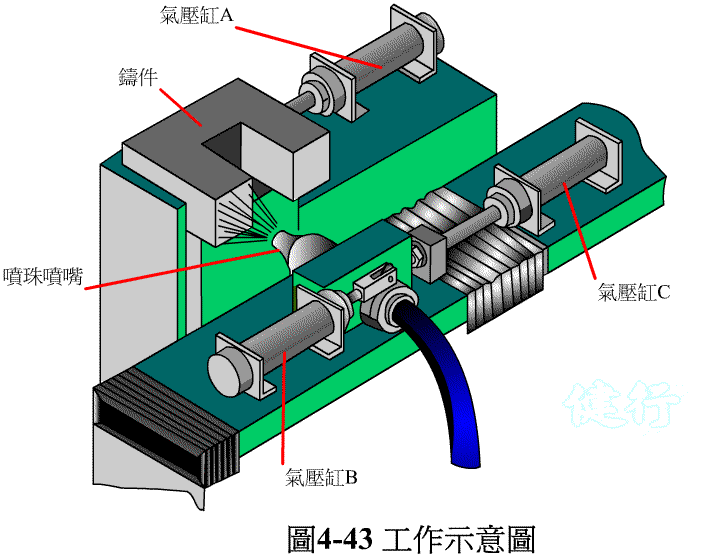
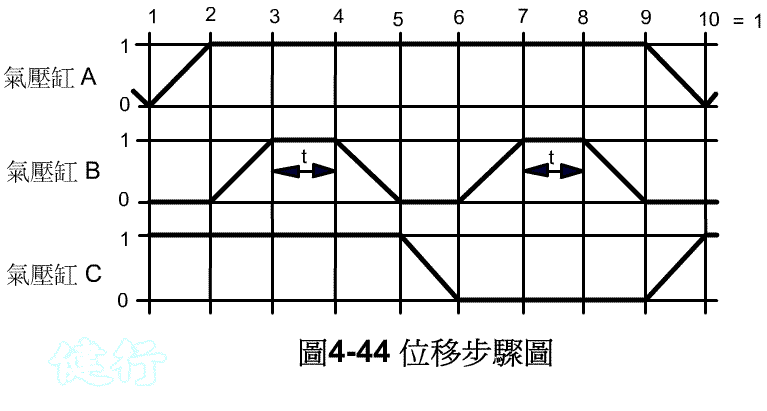
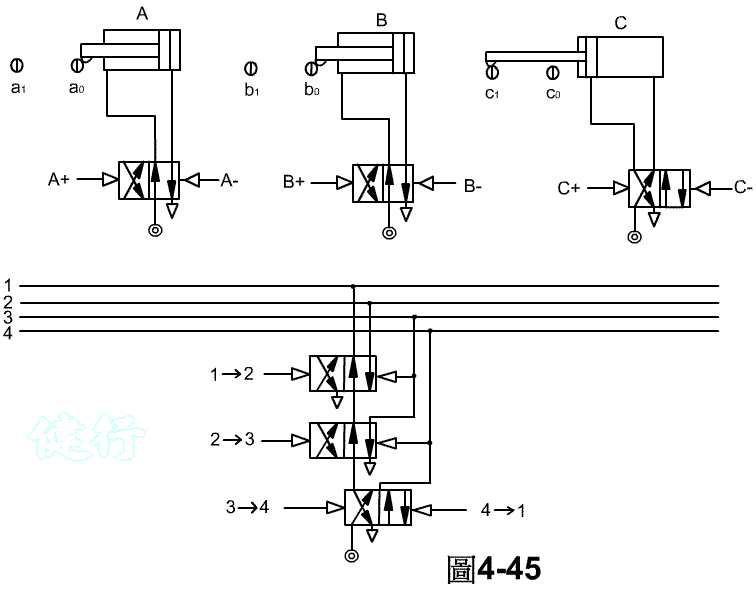
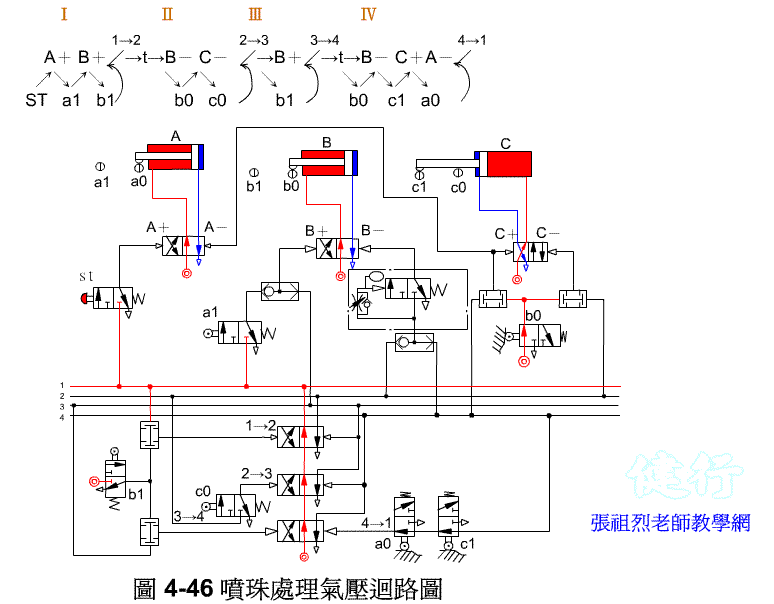
Example 4-9 The schematic diagram of the bead blasting work and the displacement steps of the casting are shown in Figure 4-43 and 44. TOP


Step 6 : Connect the relevant signals to complete the circuit design. TOP
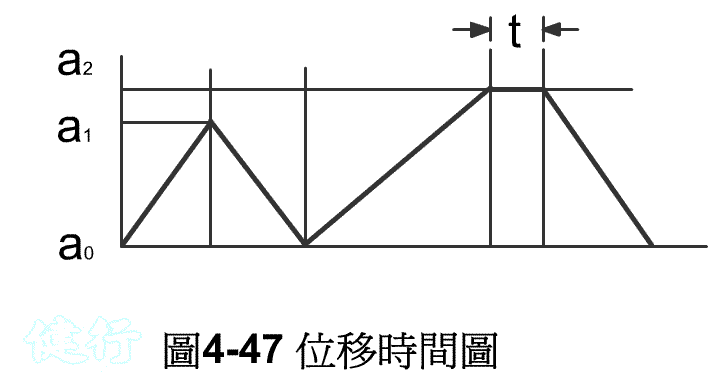
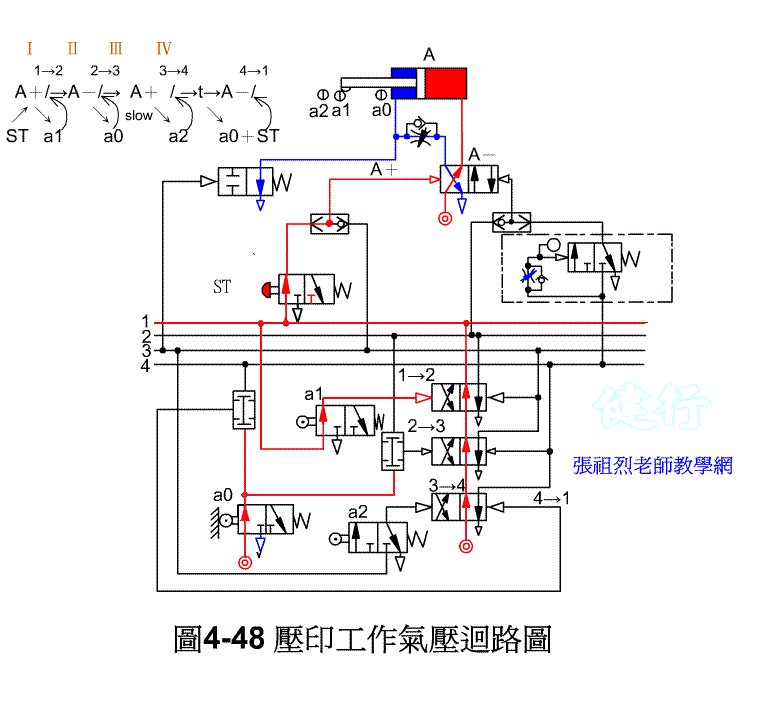
The displacement steps of Example 4-10 are shown in Figure 4-47. TOP
The signal flow is: TOP

4-4 Cycle Step Control Circuit Design Method TOP

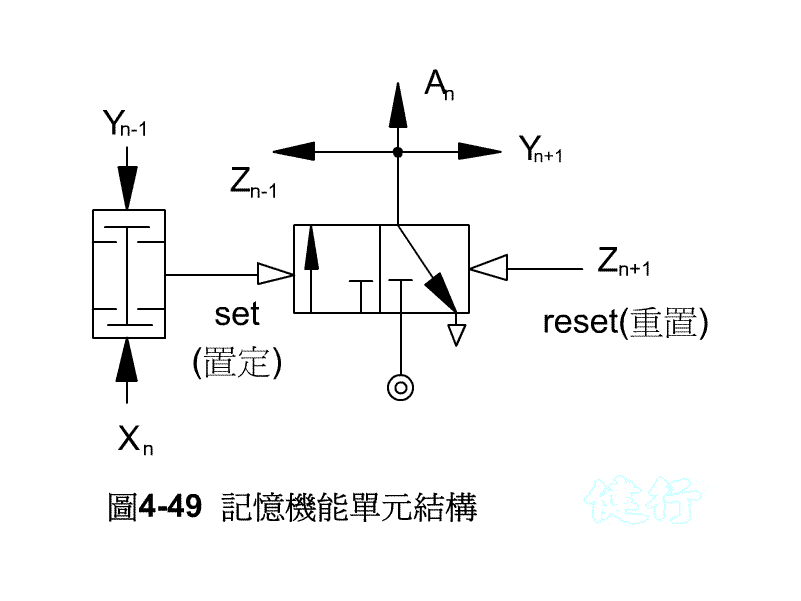
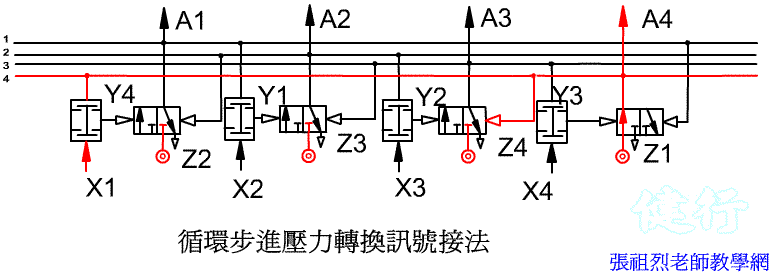
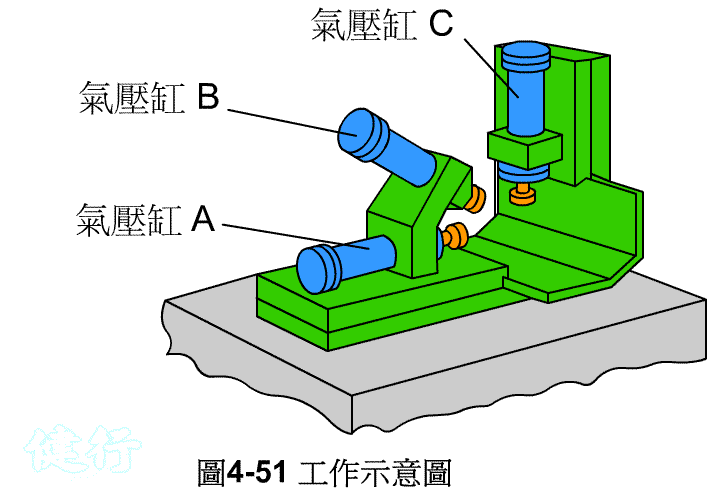
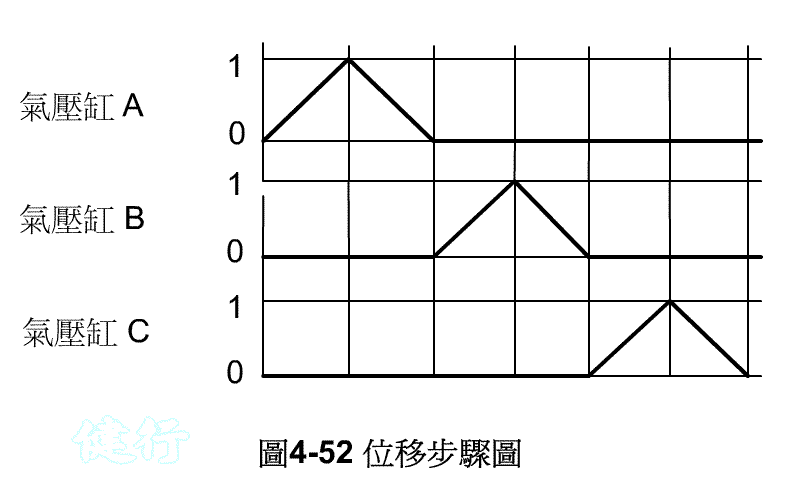
Example 4-11 Printing logo continuously. Figure 4-51 is its schematic diagram. Figure 4-52 shows the displacement steps. TOP

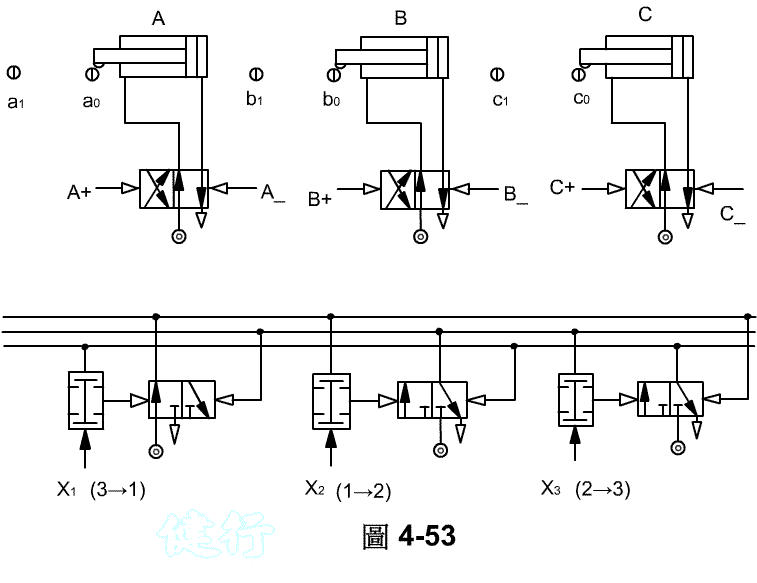
Step 5 : Find the signal flow. TOP

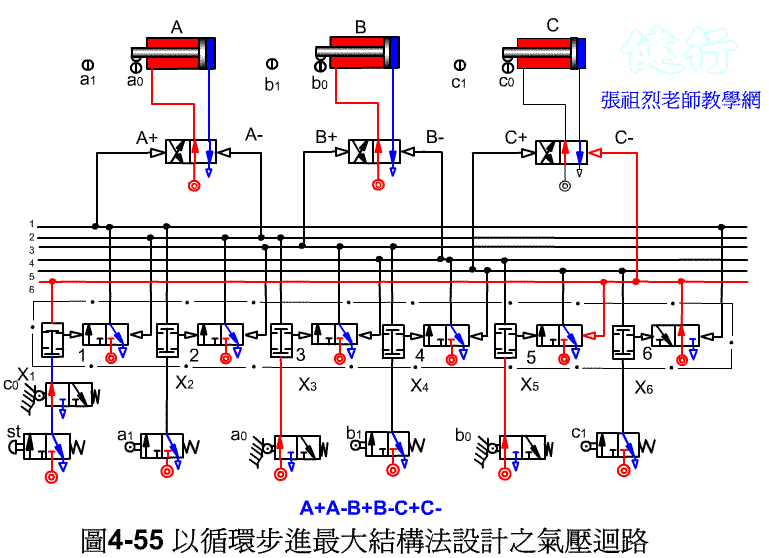
Step 6 : Connect related signals and add auxiliary conditions to complete the circuit design.
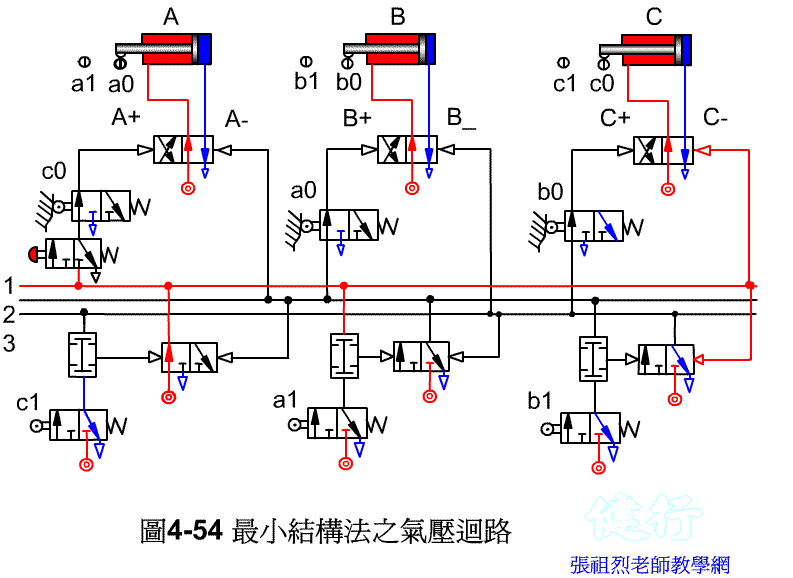
Designed by maximum structure method: TOP

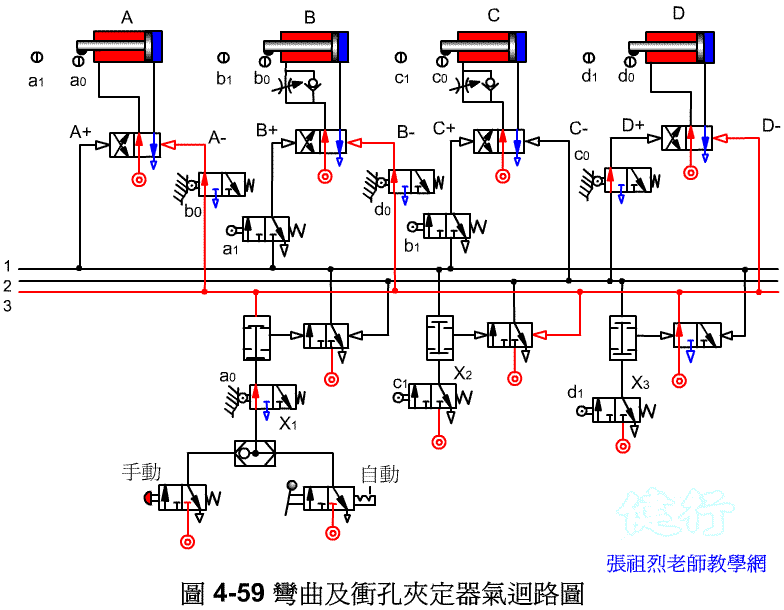
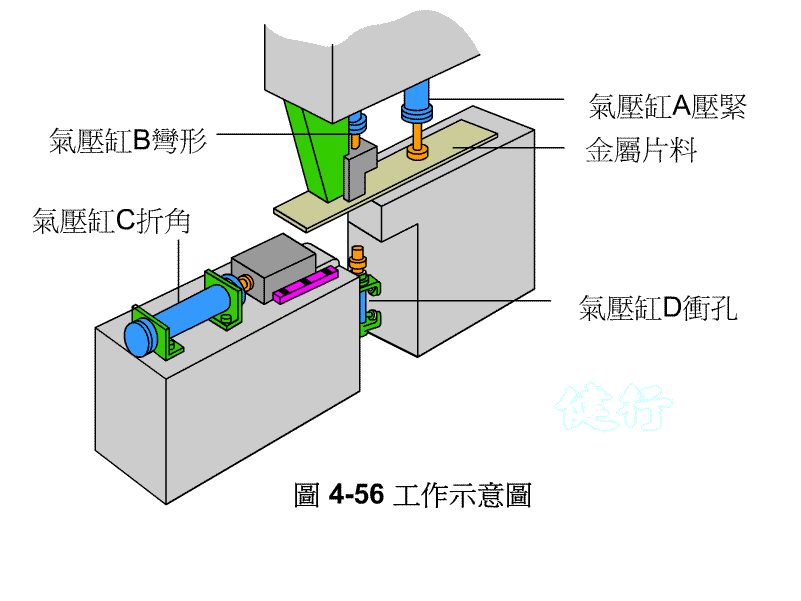
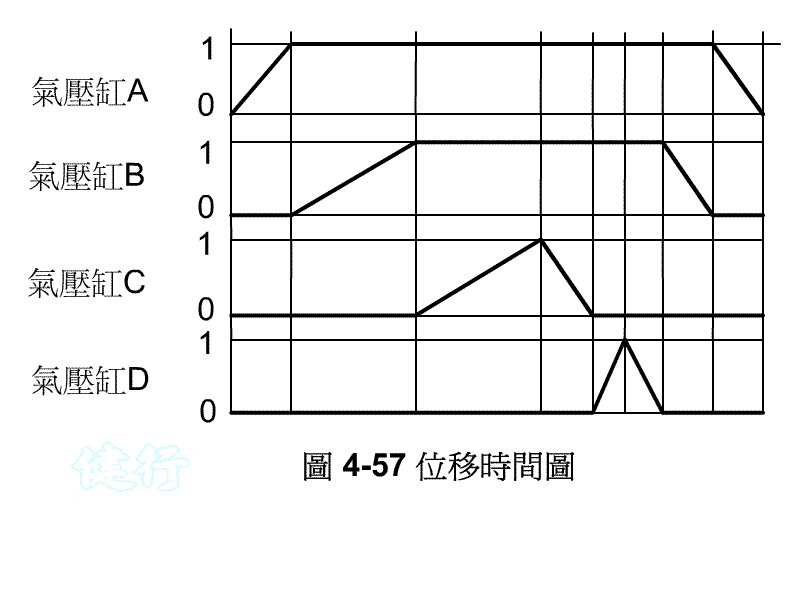
Example 4-12 bent and punched clamp, Figure 4-56 is the schematic diagram of this work. Figure 4-57 is the displacement time chart. TOP
Step 1 : List
exercise sequences. 
Step 2 : Classification. TOP
Step 3 : Draw the pressure conversion signal.
Step 4 :
Draw the drive elements, direction control elements and corresponding limit
switch positions and name them in alphabetical form.
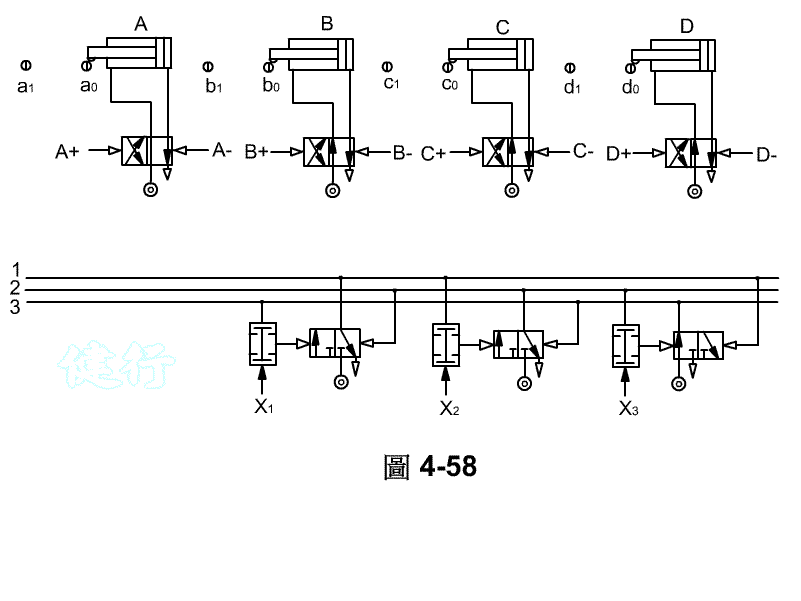
Step 5 : Find the signal flow. TOP

Step 6 : Connect the relevant signals, add auxiliary conditions (B , C speed control required,Manual and automatic selection) to complete the circuit design. TOP
GOTO Chapter 5 Electrical-Pneumatic Control
Goto Zulie teacher teaching network Pneumatic hydraulic control practice